Hexabot
•
Designflows 2025
•
Hexabot • Designflows 2025 •
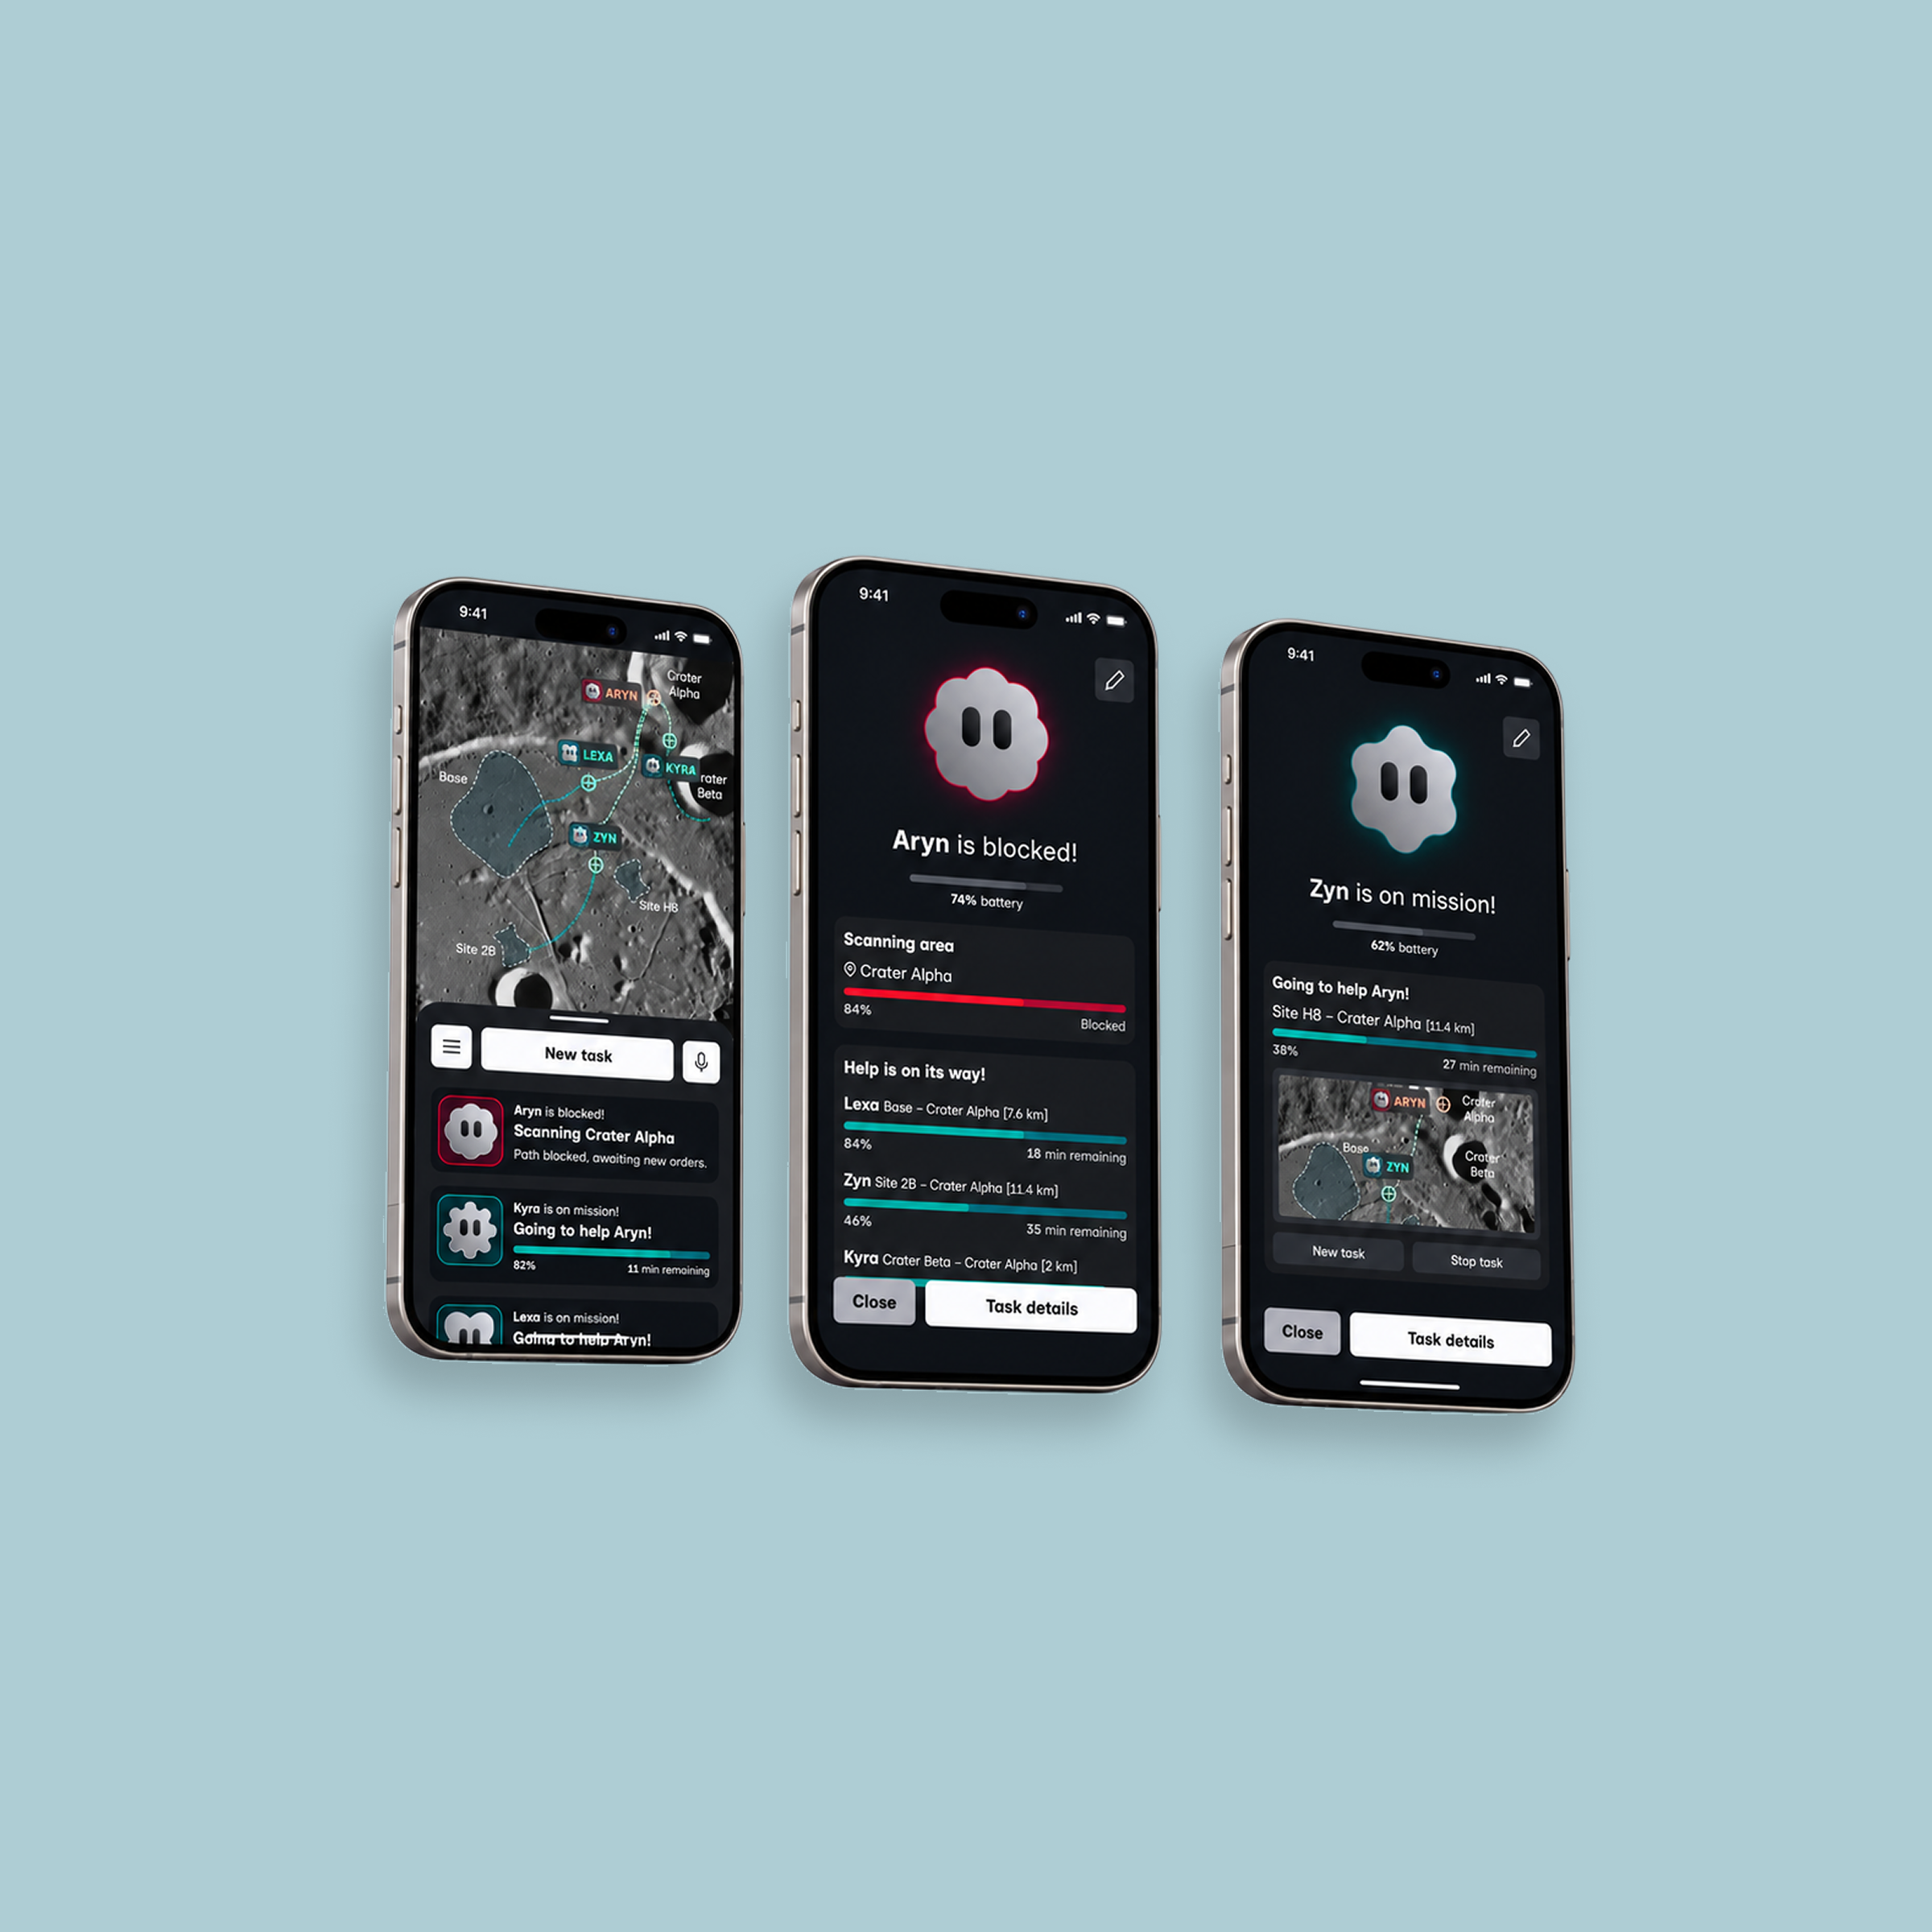
A mobile app concept for managing multi-purpose robots in a lunar colony, created for Bending Spoons’ Designflows 2025 competition. The experience brings together robot status, task assignment, and mission updates in a single interface.
UX/UI designer
Role
2025
Year
About the project
The challenge imagined a lunar settlement where families and research teams rely on Hexabots for everyday activities and essential missions. The goal was to design an app that helps them assign tasks, monitor progress, and respond to updates.
The brief focused on a resource collection scenario: checking robot availability, assigning a mission, and following its progress until the robot returns to base. The submission required a wireflow of up to twelve screens and three high-fidelity screens.
Analysis & exploration
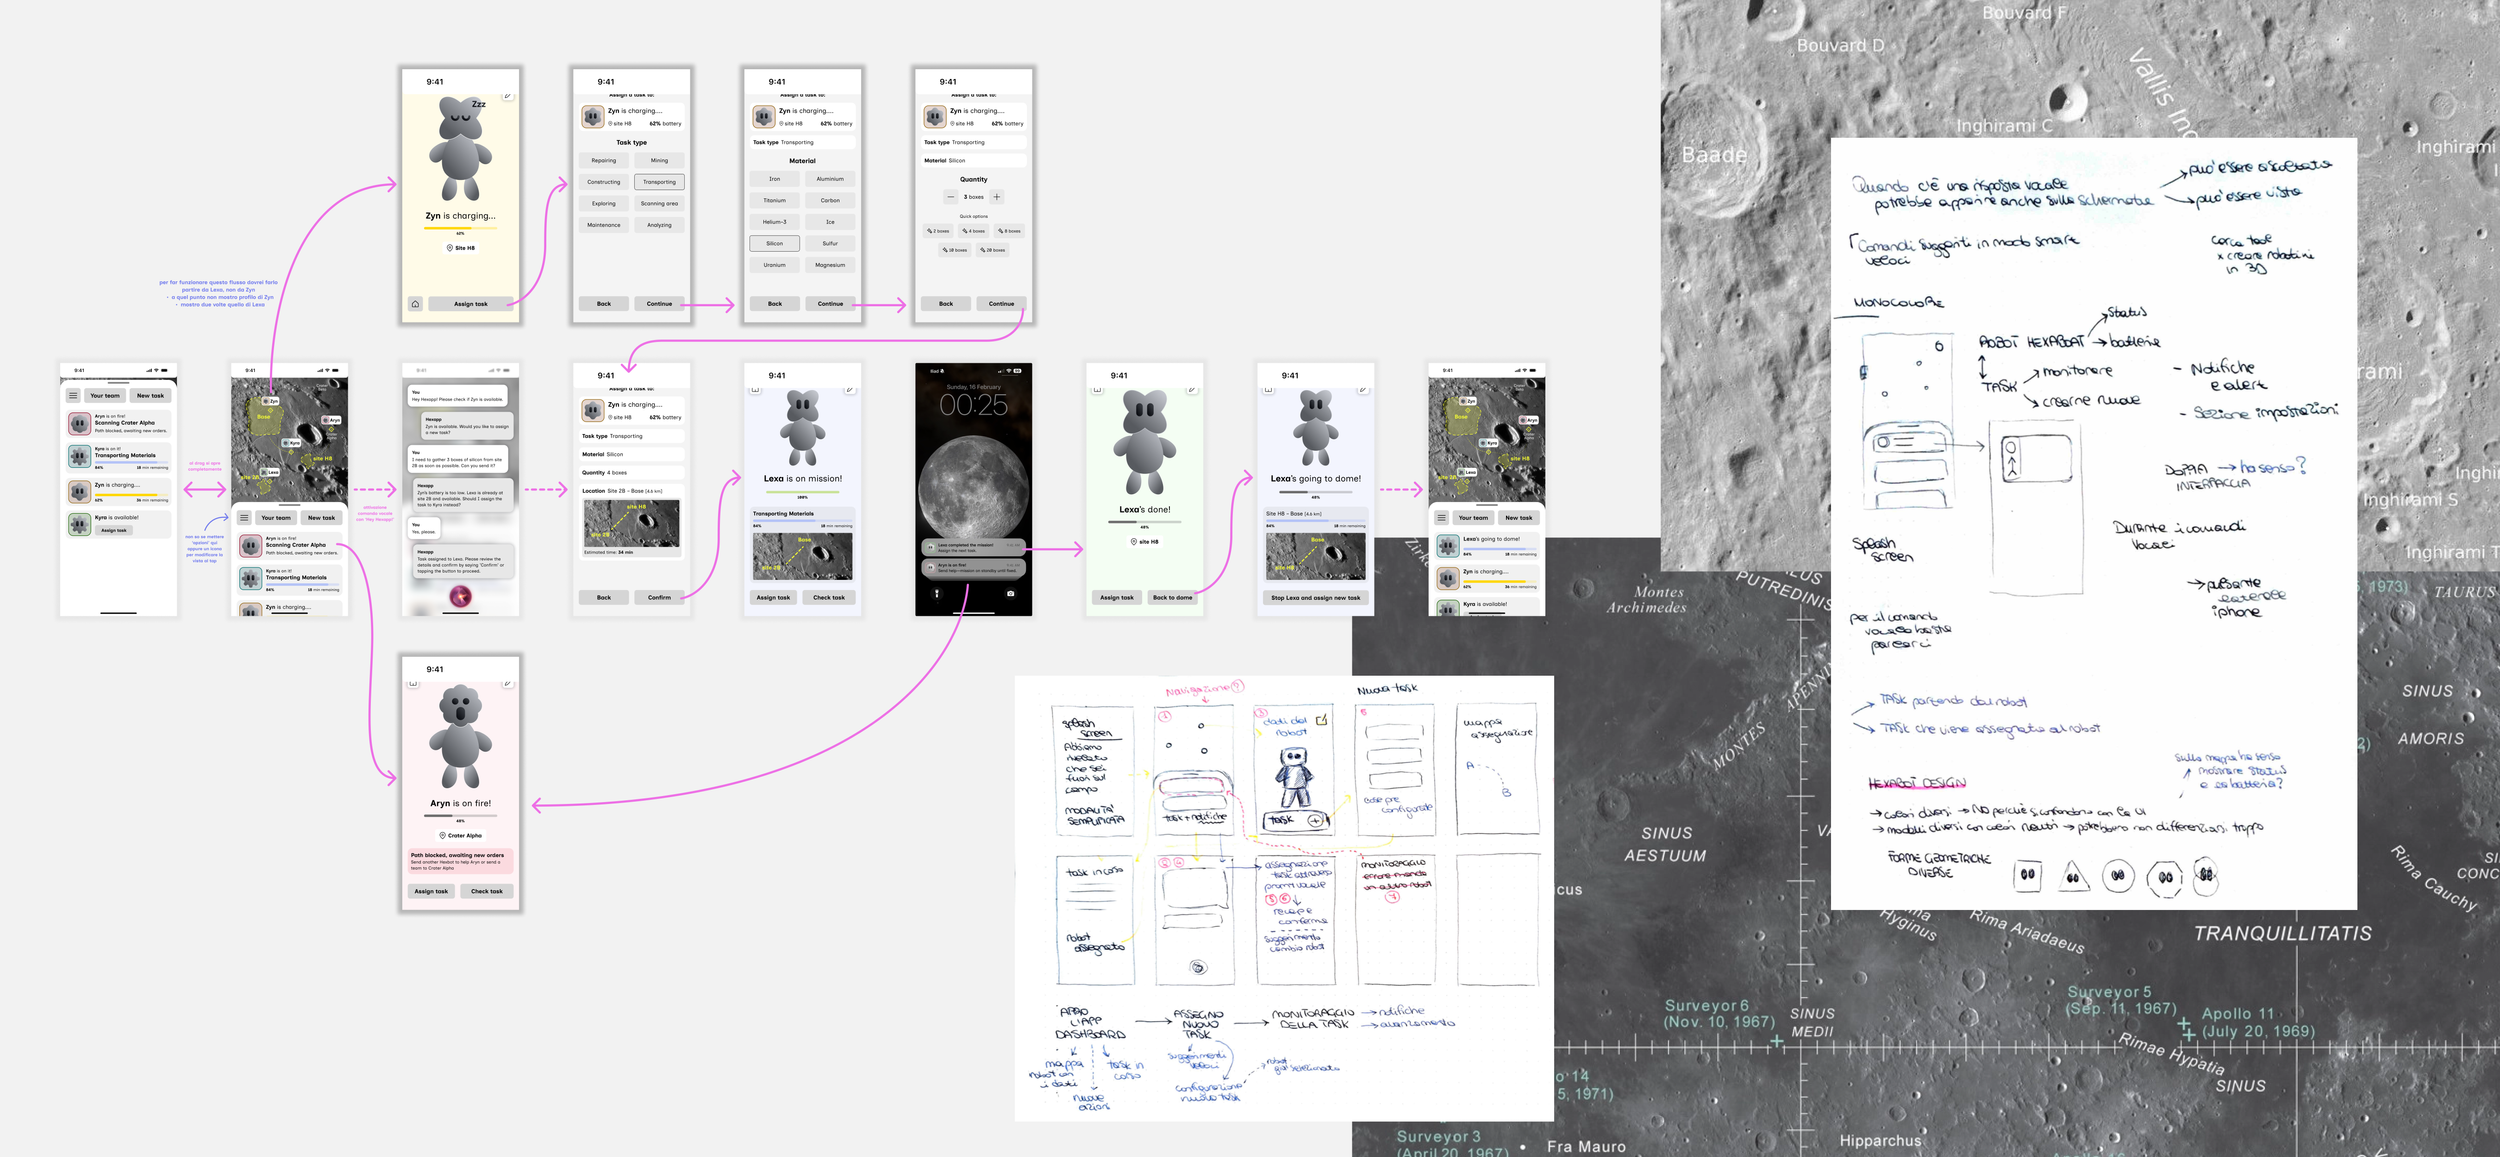
I started by breaking down the scenario and the user insights provided in the brief. Frequent status checks, urgent task assignments, and situations where touch interaction could be difficult shaped the priorities: visible status information, guided task setup, and an alternative way to interact through voice.
Through brainstorming, hand-drawn sketches, and explorations in Miro, I worked through the information hierarchy and the sequence of actions before developing the interface in Figma.
Design process
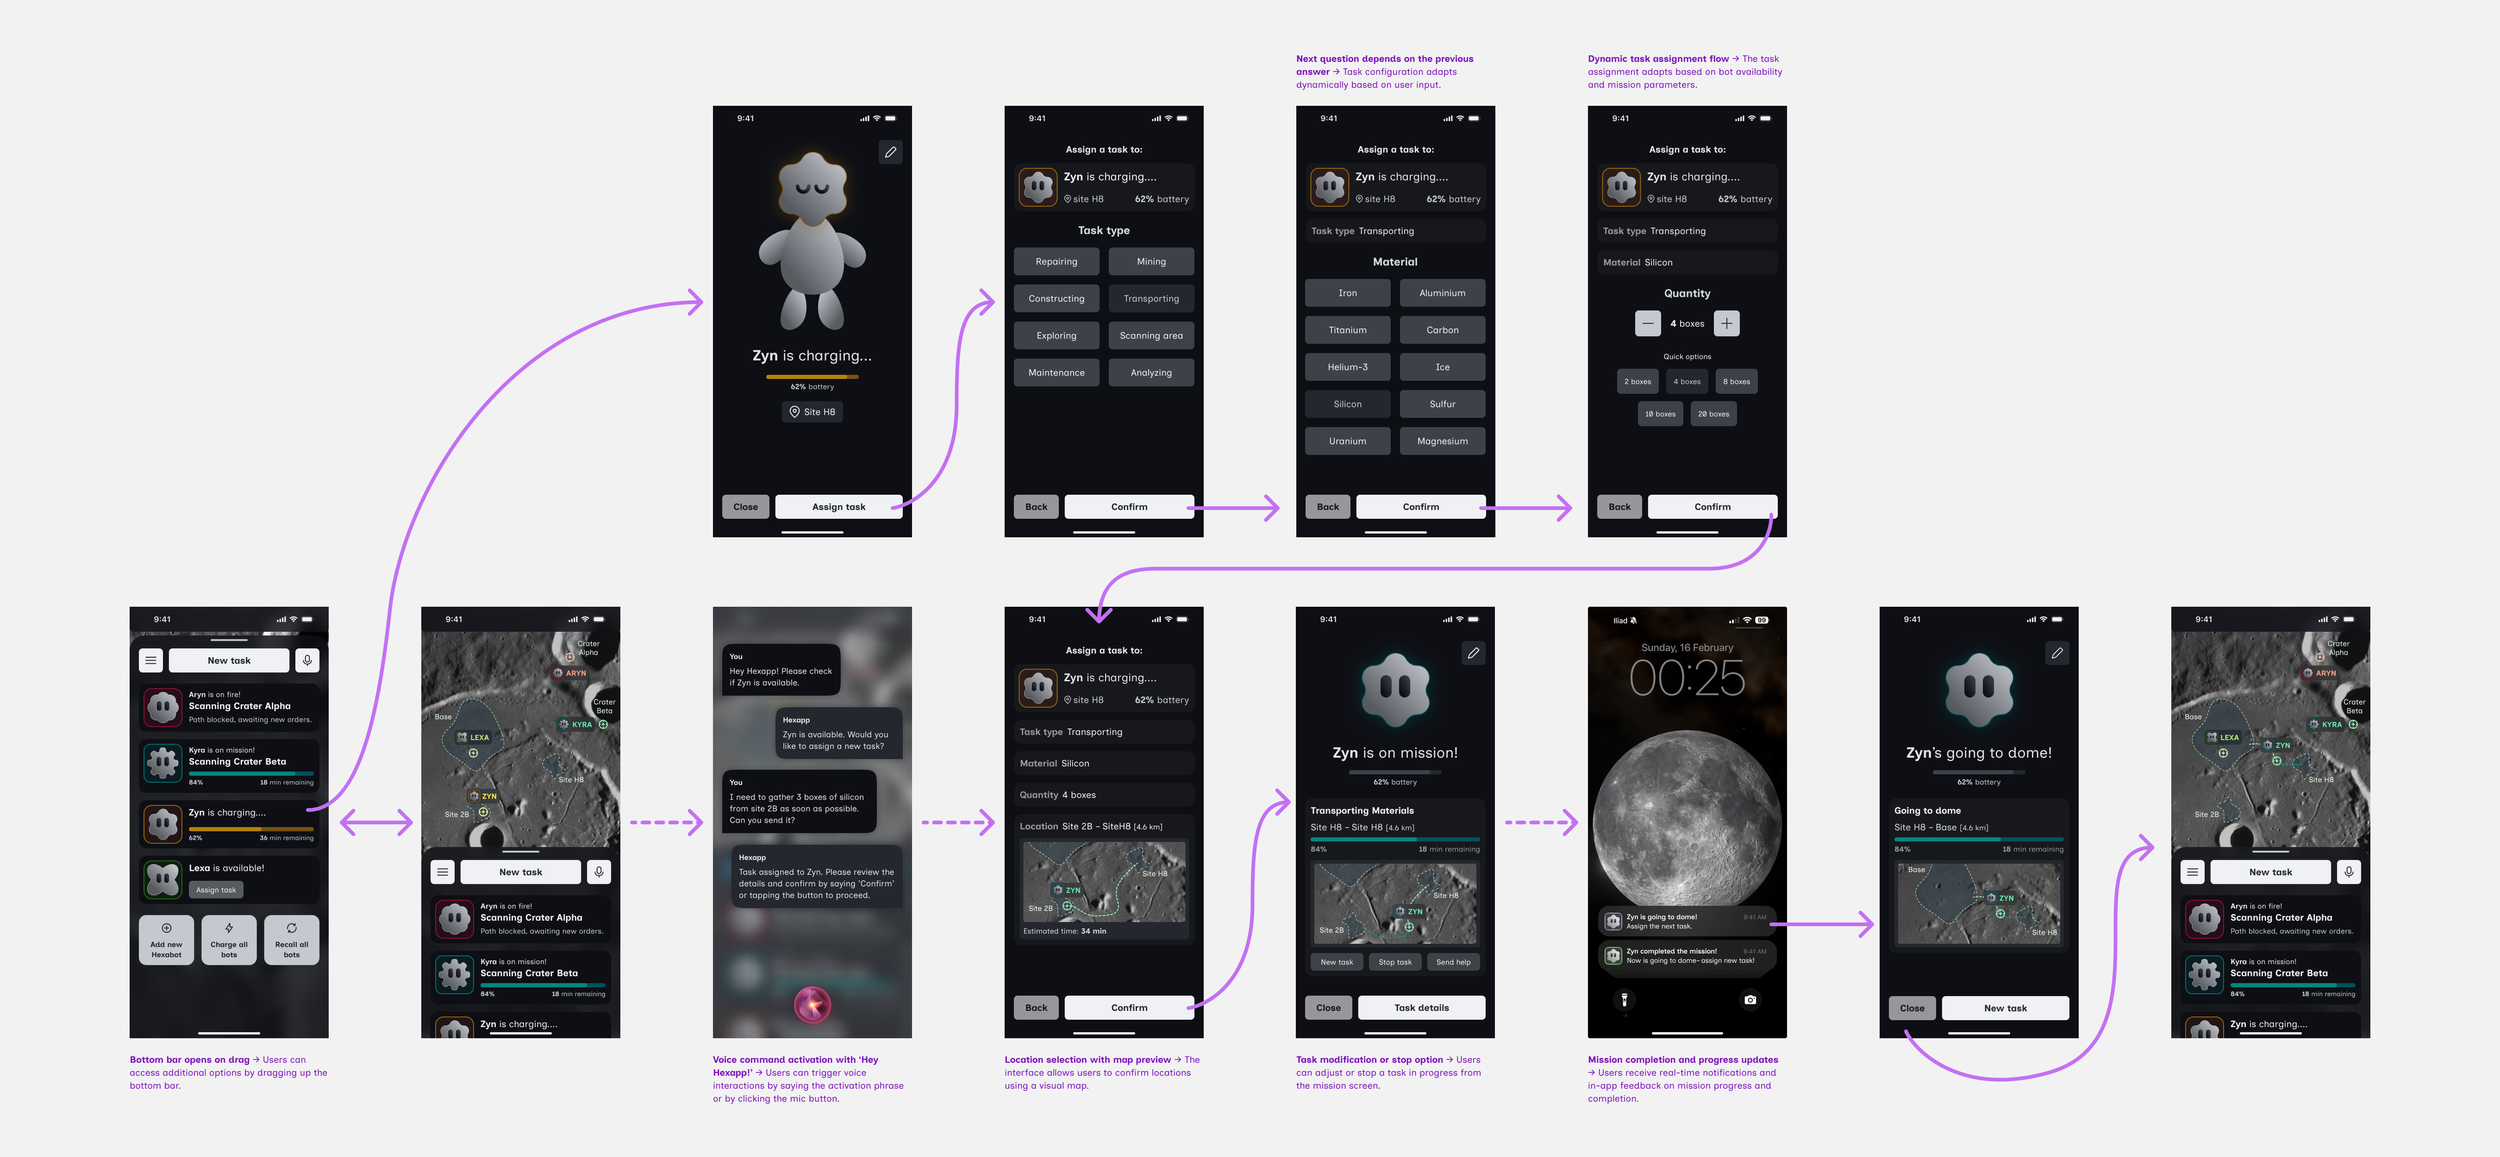
The dashboard combines a map with an expandable panel of robot statuses and ongoing tasks. The map provides location context, while the panel brings together progress, battery levels, and alerts. Names and distinct avatar shapes help users identify individual Hexabots across the interface, while colour communicates their current status.
Task assignment follows a guided sequence, from choosing an activity to specifying materials and quantities, then reviewing the mission details and route before confirmation. I also explored a voice-assisted path for checking availability and preparing a task, with a summary to review before starting the mission.
Once a task is underway, the mission screen shows progress, estimated time remaining, and options to stop the task or request help. Notifications carry the journey through to completion and the robot’s return to base.
Visual direction
I paired a dark interface and lunar map imagery with characterful robot avatars to balance the technical setting with a more approachable feel. Clear action labels and contrasting controls establish a consistent hierarchy across the dashboard, task setup, and mission screens.
Personalisation & recognition
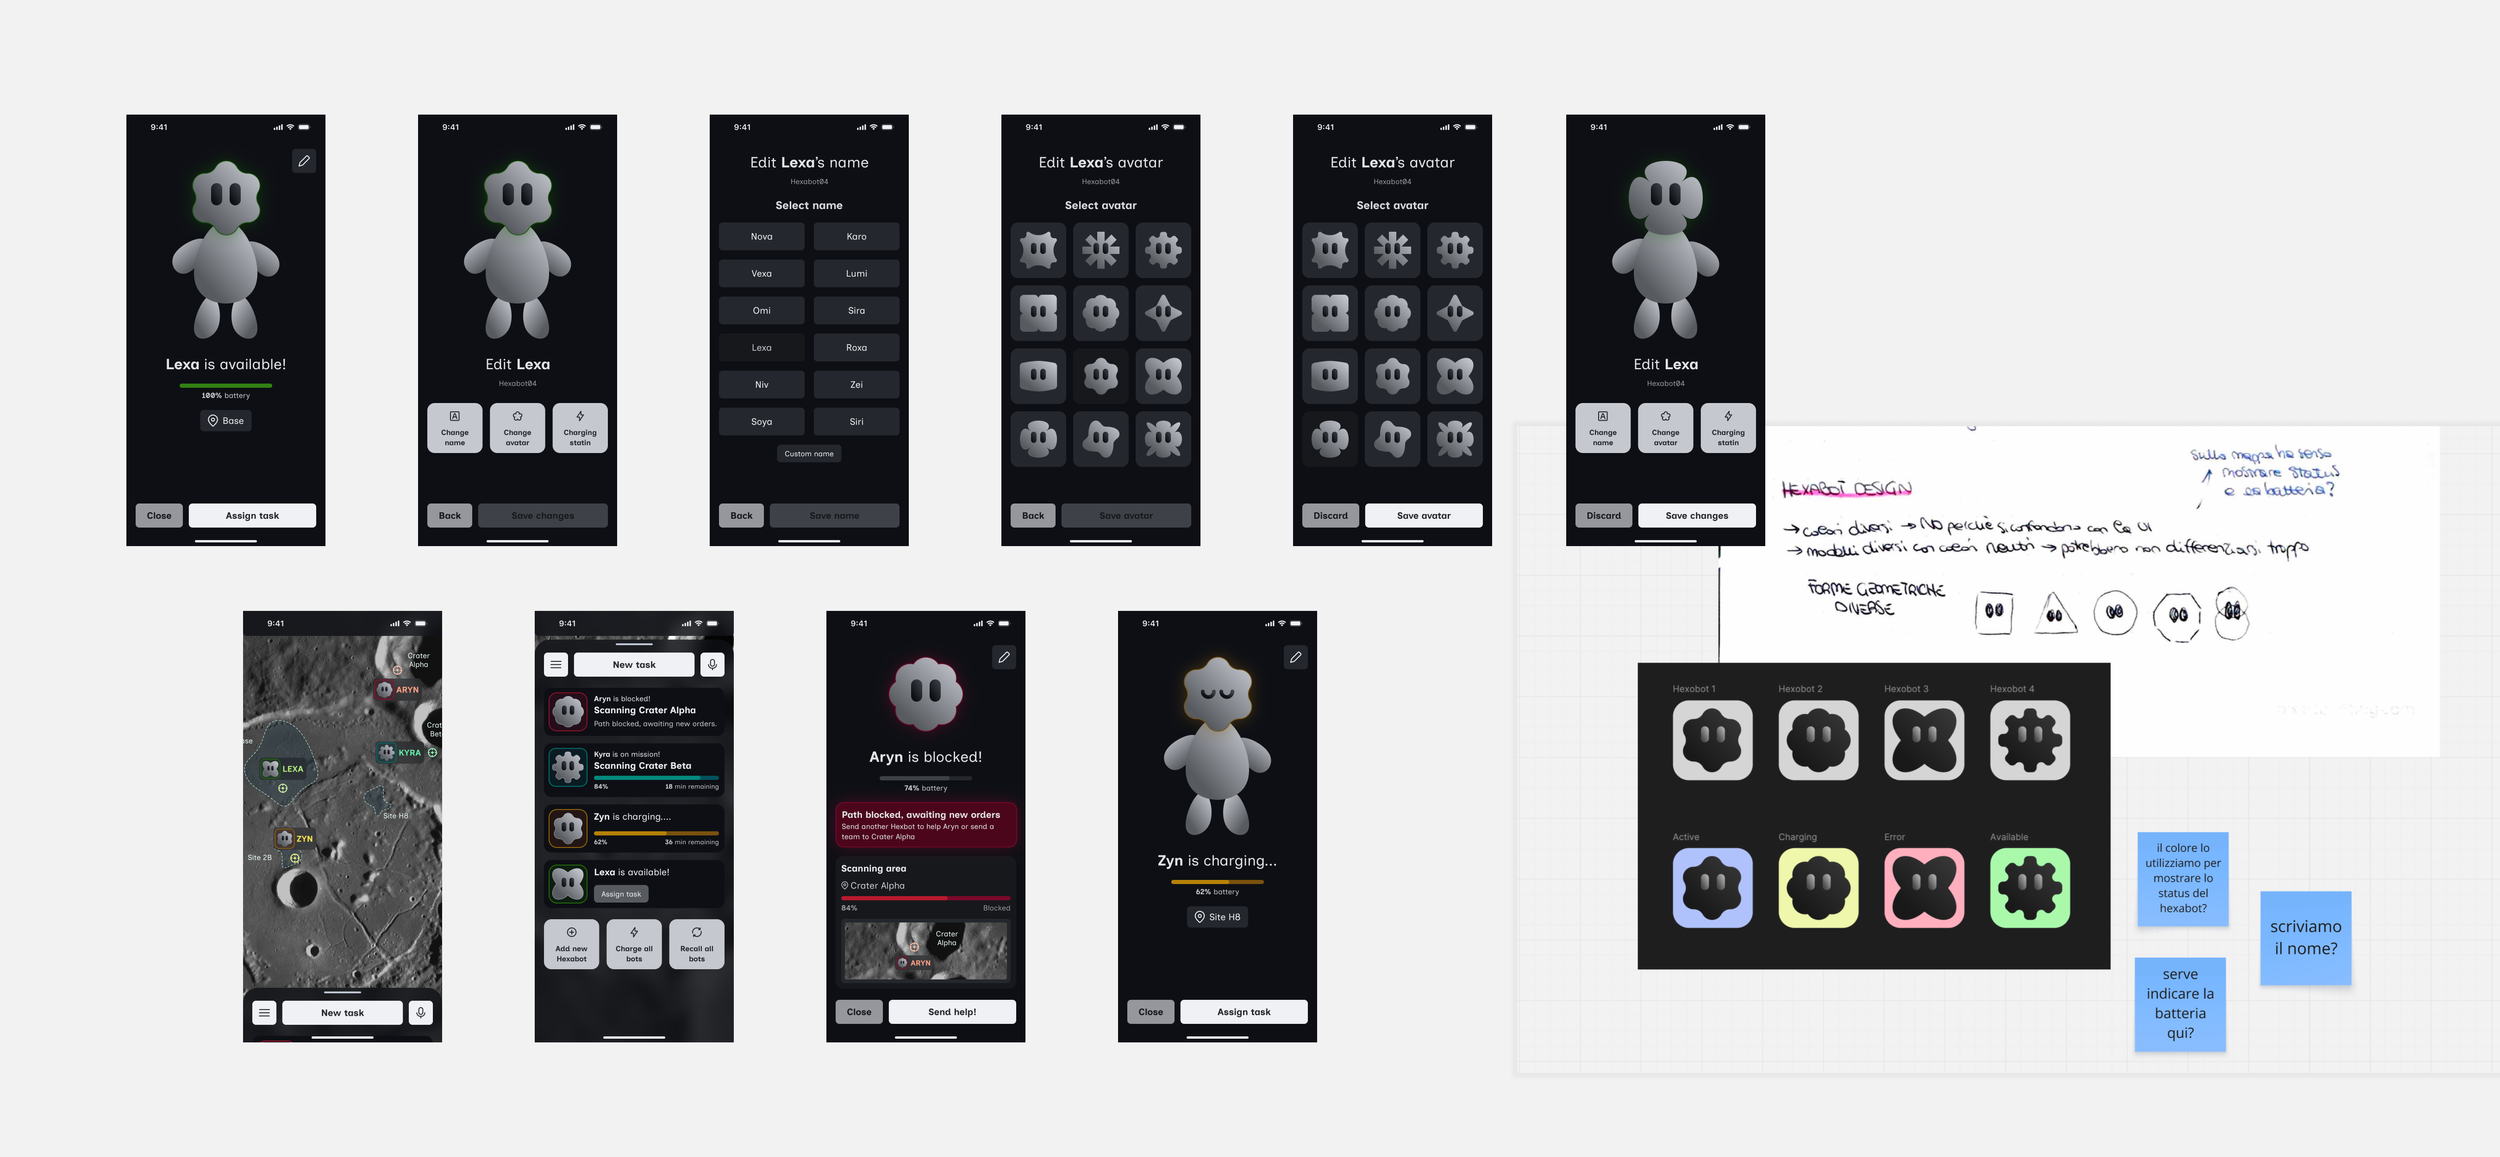
I designed a library of robot avatars with distinct shapes, allowing users to personalise each Hexabot alongside its name. The characters share a consistent visual style, with different silhouettes that carry through from the robot profile to the dashboard and map.
Personalisation also serves a practical purpose: shape identifies the robot, while colour indicates its current status. This gives each Hexabot a recognisable identity that stays consistent as it moves between tasks, charging, and availability.
Final results
•
Final results •
Explore the prototype
The final concept connects the journey from checking a Hexabot’s status to assigning and tracking a mission. Explore the interactive prototype or watch the walkthrough below.